General perspective transformation, Computer Graphics

Assignment Help:

General Perspective transformation w.r.t. an arbitrary center of projection

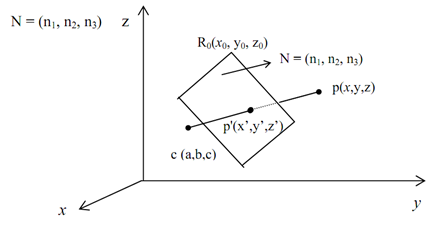
Suppose here that the COP is at C(a,b,c), as demonstrated in Figure.

By Figure, the vectors CP and CP' have the simila direction. The vector CP' is a factor of CP, which is CP'=α. CP

Hence, (x'-a)= α.(x-a)                                  z

(y'-b)= α.(y-b)

(z'-c)= α.(z-c)
1163_General Perspective Transformation.png

We know about the projection plane passing via a reference point R0(x0,y0,z0) and consisting a normal vector N= n1I+n2J+n3K, satisfies the subsequent equation:

n1.(x-x0)+n2.(y-y0)+n3.(z-z0)=0

When P'(x',y',z') lies upon this plane then we have:

n1.(x'-x0)+n2.(y'-y0)+n3.(z'-z0)=0

now substitute the value of x', y' and z' then we have:

α= (n1.(x0-a)+n2.(y0-b)+n3.(z0-c))/( n1.(x-a)+n2.(y-b)+n3.(z-c))

=((n1.x0+n2.y0+n3.z0)-(n1.a+n2.b+n3.c))/(n1.(x-a)+n2.(y-b)+n3.(z-c))

=(d0-d1)/(n1.(x-a)+n2.(y-b)+n3.(z-c))

=d/(n1.(x-a)+n2.(y-b)+n3.(z-c))

Currently,  d=d0-d1=  (n1.x0+n2.y0+n3.z0) - (n1.a+n2.b+n3.c)  shows  perpendicular distance from center of projection, C to the projection plane.

In order to determine the general perspective transformation matrix so we have to proceed as given here:

Translate COP, C (a, b, c) to the origin.  Now, R'0=(x0-a, y0-b, z0-c) turn sinto the reference point of the translated plane which is normal vector will remain similar.

By applying the general perspective transformation as Pper,N,R'o

Now translate the origin back to C as.
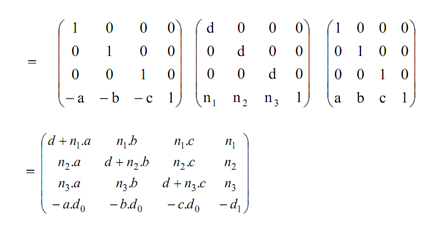
116_General Perspective Transformation 2.png

Here d = N.CR' 0 = d0 - d1 = (n1. x0 + n2. Y0 + n3.z0) - (n1.a+n2.b +n3.c)

= n1. (x0 - a) + n2. (y0 - b) + n3. (z0 - c)

And also d1 = n1.a + n2.b + n3.c


Related Discussions:- General perspective transformation

Transformation for 3-d translation, Suppose P be the point object along wit...

Suppose P be the point object along with the coordinate (x,y,z). We want to translate such object point to the new position as, P'(x',y',z') through the translation Vector as V=t x

Object space - approaches for visible surface determination, Object Space -...

Object Space - approaches for visible surface determination The second approach as object-space that compares all objects directly along with each other inside the scene defin

Perspective projections - transformation, Perspective Projections - Transfo...

Perspective Projections - Transformation In this projection the center of projection is at limited distance. This projection is termed as perspective projection since in this

Relation between 2-d euclidean system and homogeneous system, Relation betw...

Relation between 2-D Euclidean system and Homogeneous coordinate system Suppose that P(x,y) be any point in 2-D Euclidean system. In HCS, we add a third coordinate to the poin

Line drawing - points and lines, Line Drawing - Points and lines Line ...

Line Drawing - Points and lines Line drawing is accomplished through computing the intermediate point coordinates along the line path between two given end points. Since, scre

Draw line segment - digital differential analyzer algorithm, 1. By using D...

1. By using Digital Differential Analyzer algorithm draw line segments from point (1,1) to (9,7). Ans. We see that the usual equation of the line is specified by: y = mx+c

Gourand shading, what is ray tracing algorithm in hidden surface removal

what is ray tracing algorithm in hidden surface removal

Introduction of visible surface detection, Introduction of Visible Surface ...

Introduction of Visible Surface Detection For displaying a realistic presentation of the given 3Dimentional object, hidden surfaces and hidden lines should be identified fo

Write Your Message!

Captcha
Free Assignment Quote

Assured A++ Grade

Get guaranteed satisfaction & time on delivery in every assignment order you paid with us! We ensure premium quality solution document along with free turntin report!

All rights reserved! Copyrights ©2019-2020 ExpertsMind IT Educational Pvt Ltd